
 Script Planner Assistant▸
 AI Apps
 AI News
Being-M0: A Universal Humanoid Robot Motion Generation Framework with Data-Model Synergy
小编 ·

Being-M0: A Universal Humanoid Robot Motion Generation Framework with Data-Model Synergy
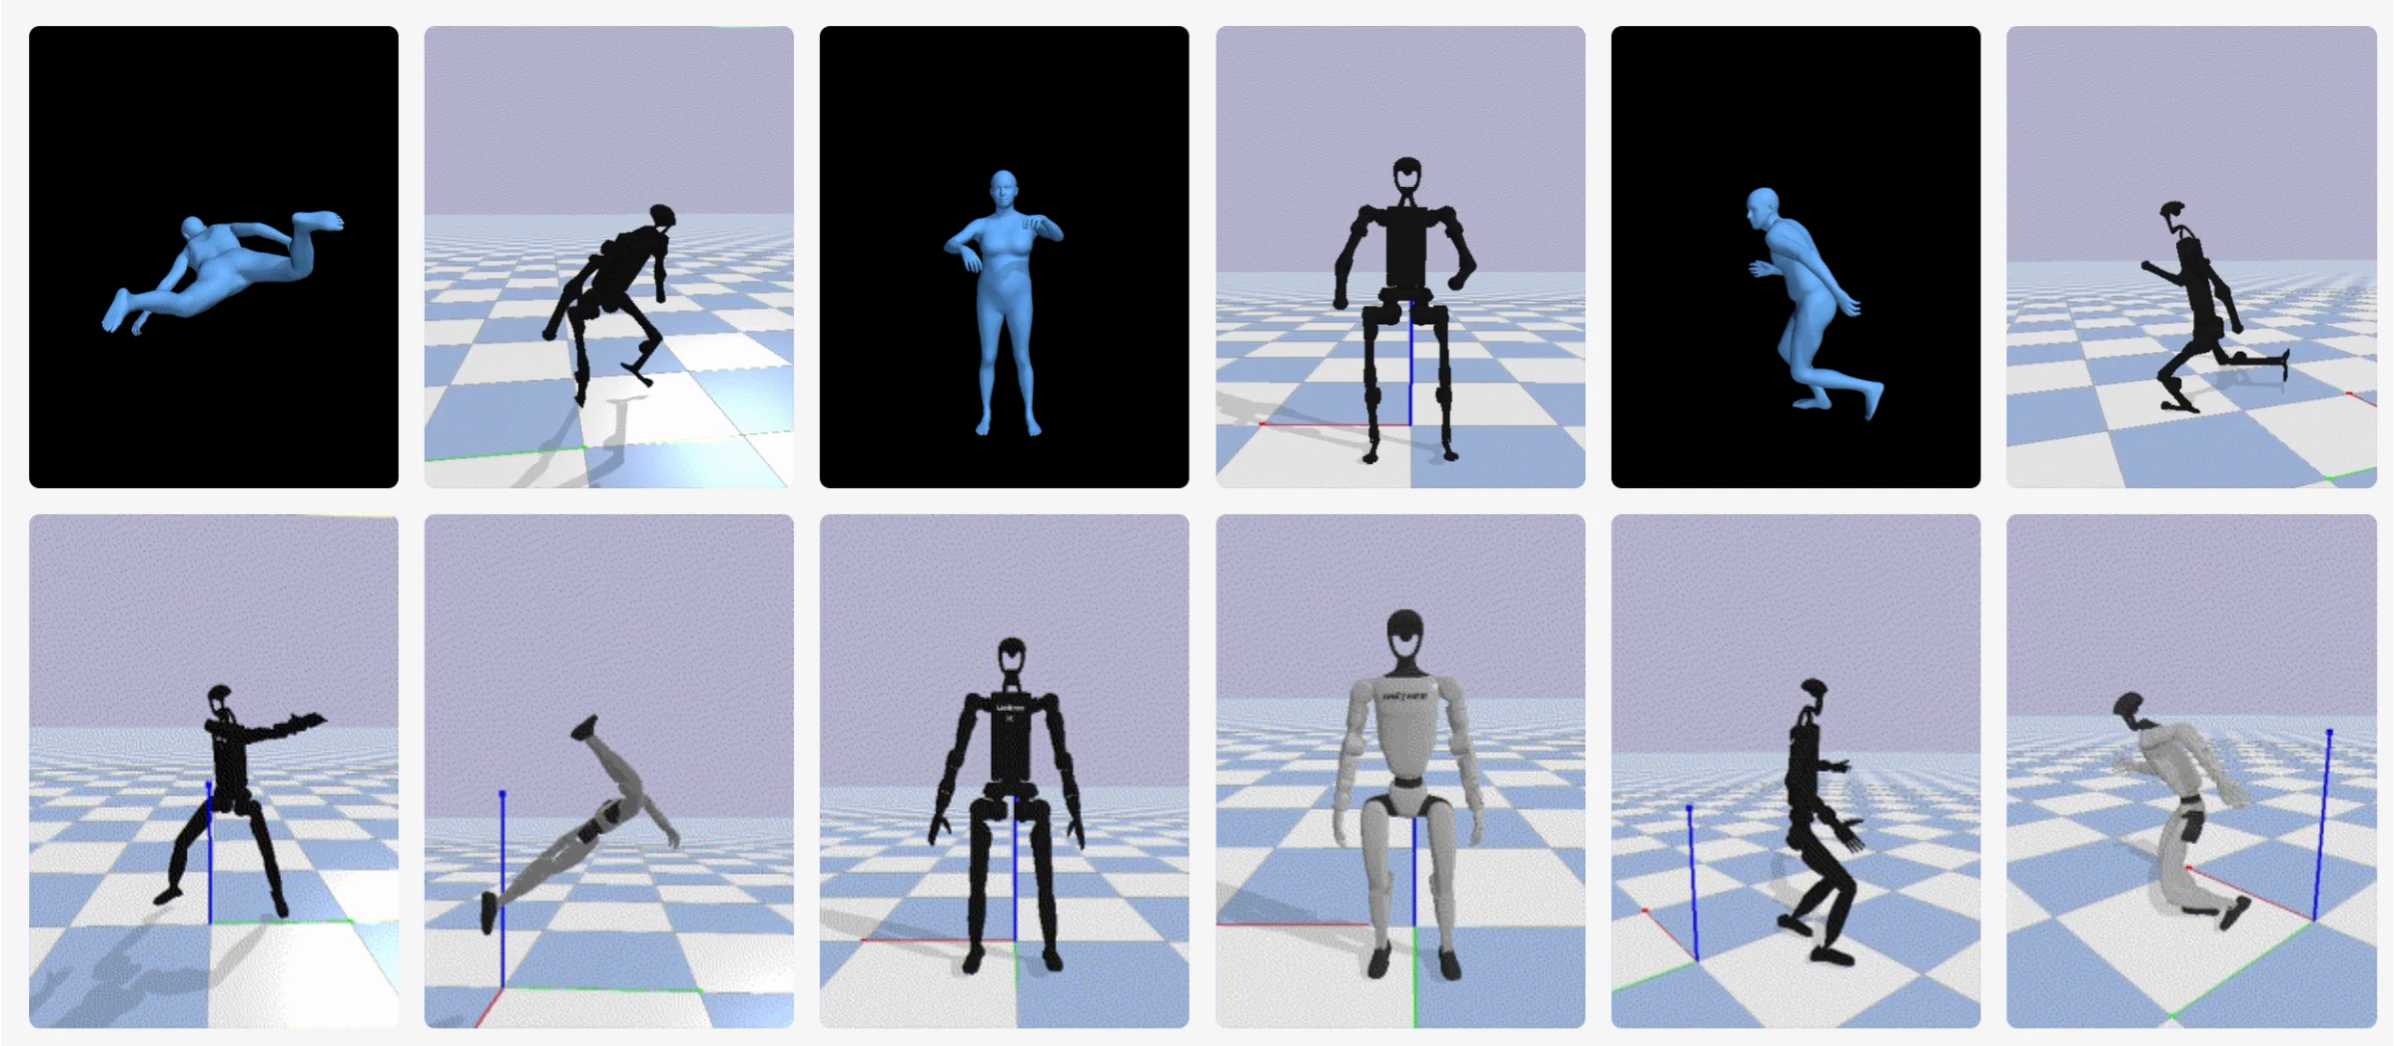
Research teams from Peking University and Renmin University of China have made significant progress in motion generation for humanoid robots. They developed a universal motion generation framework called Being-M0 and created MotionLib, the first million-scale motion generation dataset. This dataset extracts high-quality motion data through an innovative data processing pipeline and detailed annotation methods, supporting multiple data formats. Research results show that leveraging large amounts of data and powerful models can effectively enhance motion generation. The team also proposed MotionBook, a new motion encoding method that further optimizes motion generation results. In addition, they combined optimization- and learning-based methods to efficiently apply human body motions to various humanoid robots, providing strong support for the development of humanoid robots.
Dataset MotionLib
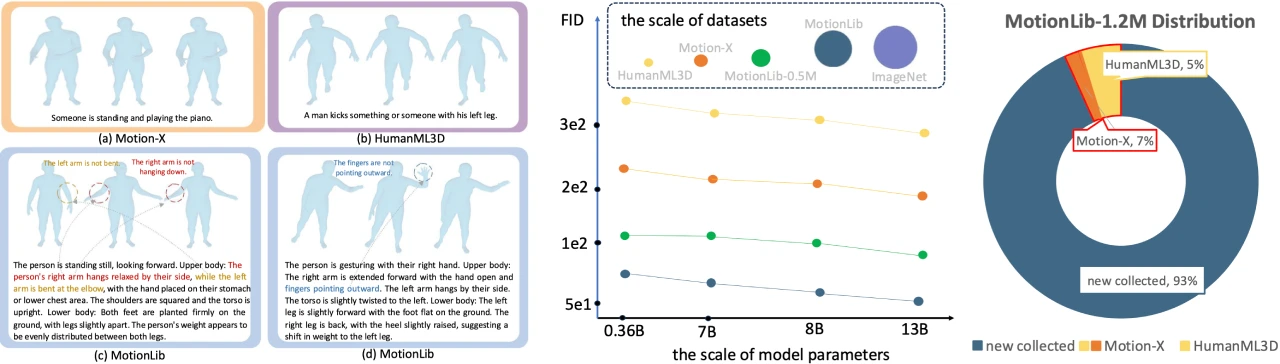
Scale and Annotation: MotionLib is the industry's first million-scale motion generation dataset, containing over 1.2 million motion sequences with hierarchical and detailed text annotations. The dataset systematically collected over 20 million human motion videos from public datasets and online platforms, and developed an innovative data processing pipeline.
Data Optimization: To improve data quality, the team used pre-trained models for 2D human keypoint estimation, filtered results through confidence thresholds, and then utilized advanced models to generate high-precision 3D keypoint data. In addition, they trained reinforcement learning-based policies to optimize the raw motions, making them more consistent with physical laws.
Motion Encoding Method MotionBook
2D Lookup-Free Quantization: MotionBook is proposed, modeling motion sequences as single-channel 2D "motion images," constructing independent encoding spaces along the time axis and joint axis respectively, fully preserving the multi-dimensional structural features of motion. This approach significantly expands the capacity of the motion encoder without needing to look up corresponding tokens, improving the efficiency of motion representation.
Model Being-M0
Performance and Scaling Effects: Based on MotionLib and MotionBook, Being-M0 exhibits significant scaling effects, validating the technical feasibility of "big data + big models" in the field of motion generation. Under the same data conditions, model capacity shows a significant positive correlation with generation quality. Compared to the 700M-parameter GPT2, the 13B-parameter LLaMA-2 model achieves breakthroughs in core metrics such as motion diversity and semantic alignment accuracy.
Cross-Platform Motion Transfer: An innovative fusion of optimization- and learning-based methods achieves efficient transfer of motion data to multiple humanoid robots, significantly enhancing cross-platform motion adaptation capabilities.
Project Links
Project Page:https://beingbeyond.github.io/Being-M0/
Paper Link:https://arxiv.org/abs/2410.03311
Github:https://github.com/BeingBeyond/Being-M0









